Six-axis industrial robots
Three reaches Configured to order Hawthorne, California
Advanced Metal Research
Rosie
Precise six-axis industrial arms you can program any way you like, in three reaches: 600, 1,000 and 1,400 mm. One design and one open controller, from bench cells to long welds.
Shown
$19,900 launch price · fully refundable deposit
Rosie 600: $14,900 and Rosie 1000: $19,900 per robot, launch prices for pre-orders placed before 31 December 2026. Rosie 1400: $29,000 per robot, deliveries begin Q1 2027. Every deposit is fully refundable. The balance is invoiced before shipment.
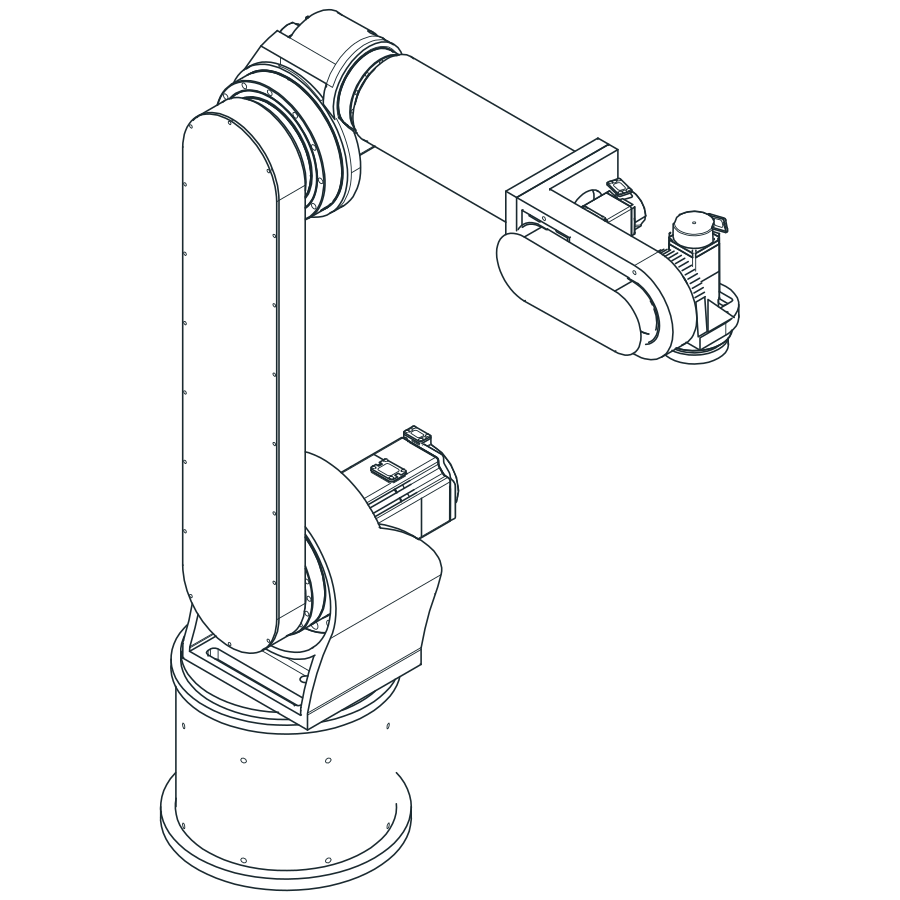
ModelsRosie 600 · 1000 · 1400600 to 1,400 mm reach
ControlRosieOSBuilt by AMR, Apache 2.0
01 Key figuresRosie 1000
- Axes
- 6
- Reach
- 1,000 mm
- Payload
- 7.4 kg
- Supply
- 220–240 V
- Controller
- RosieOS
- Price
- $19,900
Reach to the wrist centre, 1,077 mm to the tool flange. Rated payload with its centre of mass 100 mm out and 50 mm off the tool axis, in every pose. Single-phase supply on a 20 A circuit. Launch price for pre-orders placed before 31 December 2026.
02 Three reachesElevation, one scale Reach to the wrist centre
Three reaches, one design.
The same six-axis layout, wrist and RosieOS controller in three sizes. Pick the reach your cell needs.
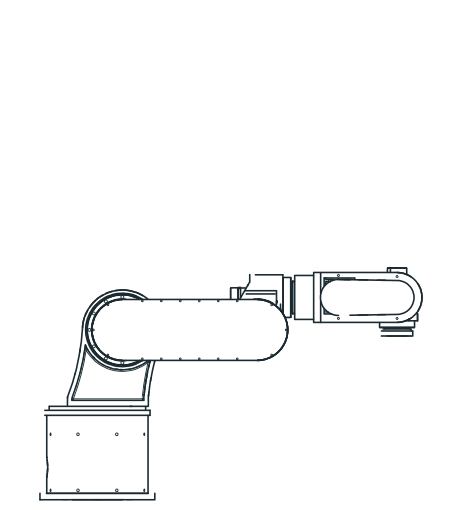
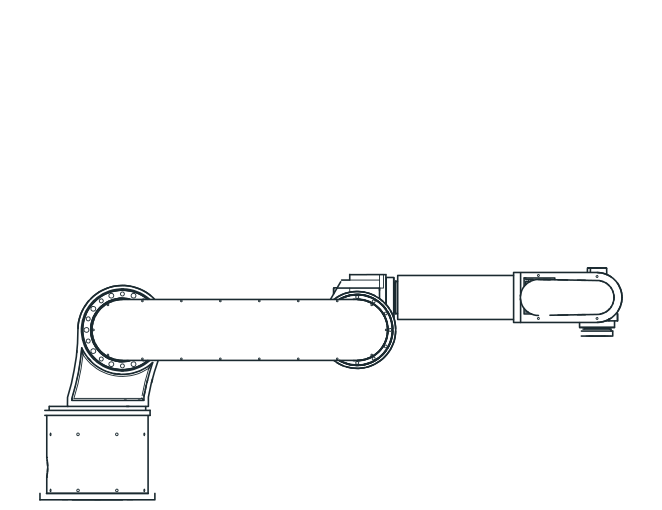
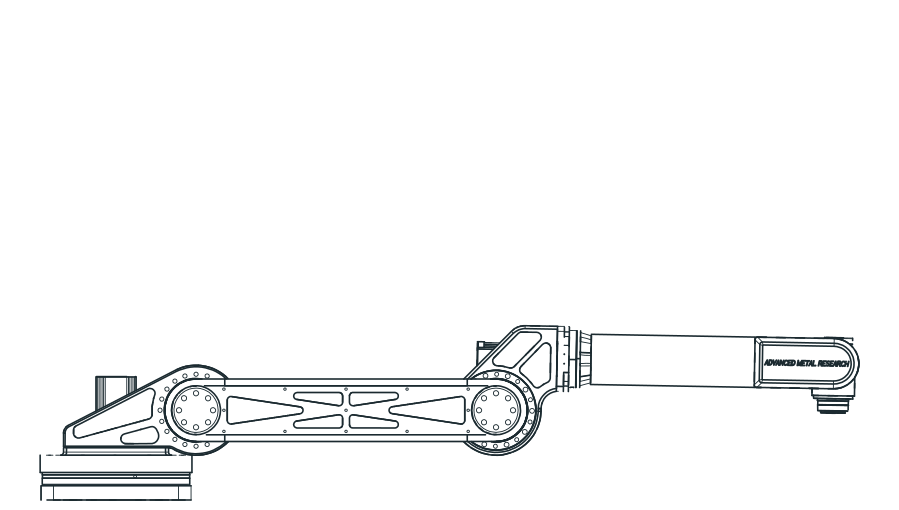
Rosie 600 and Rosie 1000 share the base, the wrist and the tool flange. The 1000 has a 470 mm upper arm and a longer forearm, with larger drives at the shoulder and elbow. Both have harmonic gearboxes and absolute encoders on all six joints. Rosie 1400 has the longest reach and the highest payload.
| Figure | Rosie 600 | Rosie 1000 | Rosie 1400 |
|---|---|---|---|
| Reach | 600 mm | 1,000 mm | 1,400 mm |
| Payload, rated | 9 kg | 7.4 kg | 15 kg nominal |
| Payload, peak | 29.7 kg | 29.7 kg | 23.4 kg |
| Repeatability | ±0.03 mm | ±0.04 mm | ±0.05 mm |
| Axes | 6 | 6 | 6 |
| Supply | 220–240 VAC, single-phase, 16 A circuit | 220–240 VAC, single-phase, 20 A circuit | 200 to 240 VAC, 3-phase, 35 A |
| Line current, peak / average | 10.8 A / 2.6 A | 16.4 A / 3.1 A | 17.4 A / 3.1 A per phase |
| Base | Ø230 floor plate, 6 × M10 anchors | Ø230 floor plate, 6 × M10 anchors | 300 × 300 mm plate, 4 × Ø26 anchors |
| Tool flange | ISO 9409-1-50-4-M6 | ISO 9409-1-50-4-M6 | Ø38 face, 6 × M5 on PCD 27, ISO 50 adapter |
| Controller | RosieOS | RosieOS | RosieOS |
| Price | $14,900 launch | $19,900 launch | $29,000 |
Pre-order Rosie 600 · $500 deposit $14,900 launch price
Pre-order Rosie 1000 · $500 deposit $19,900 launch price
Pre-order Rosie 1400 · $500 deposit $29,000 · deliveries begin Q1 2027
Launch prices are for pre-orders placed before 31 December 2026. Full figures for each model are in the specification. Line current is at 230 V, power factor 0.6, over a standard pick-and-place cycle at rated payload.
In motionHawthorne R&D lab
03 ProcessesIllustrative cycles Planned on the Rosie 1400 model
One arm, many processes.
Welding comes first. With a different end-effector and program, the same arm can handle, assemble, dispense, deburr, and cut.
Each cycle below is planned on the kinematic model of Rosie 1400 and timed to its rated joint speeds, with a conservative estimate of its acceleration. Every target is within the joint limits, and the tooling is drawn to scale. Rosie 600 and Rosie 1000 take the same kinds of tooling for parts within their reach and payload. Tell us the part and the process, and we will scope the tooling and the right Rosie with the proposal.
-
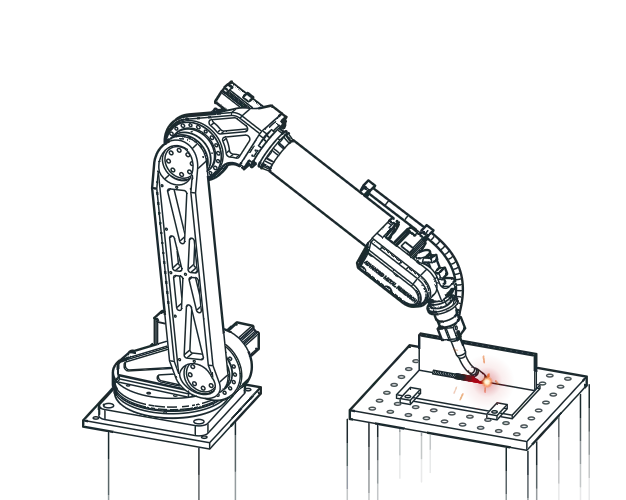 01
Welding: MIG fillet
A MIG torch lays a fillet weld along a T-joint.
-
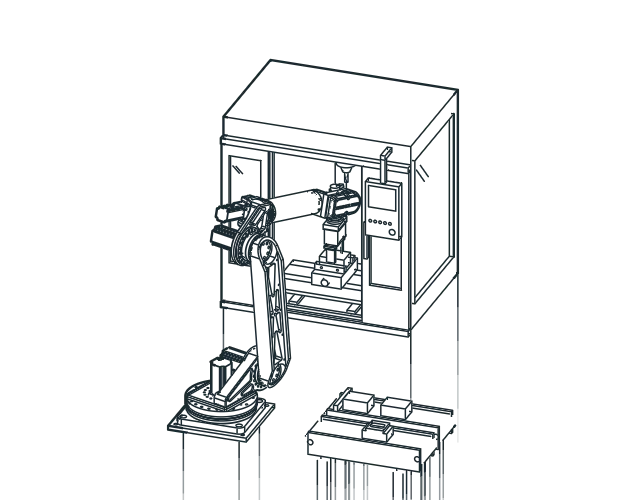 02
Machine tending
Rosie loads a blank through the machine door and unloads the finished part.
-
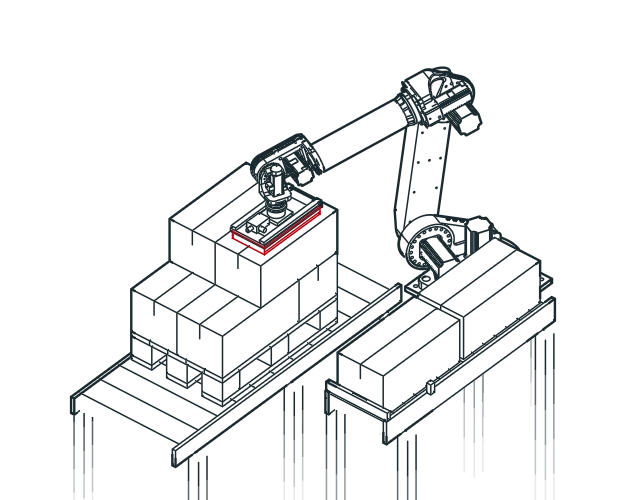 03
Palletizing
A vacuum gripper stacks cartons on a pallet in interlocked layers.
-
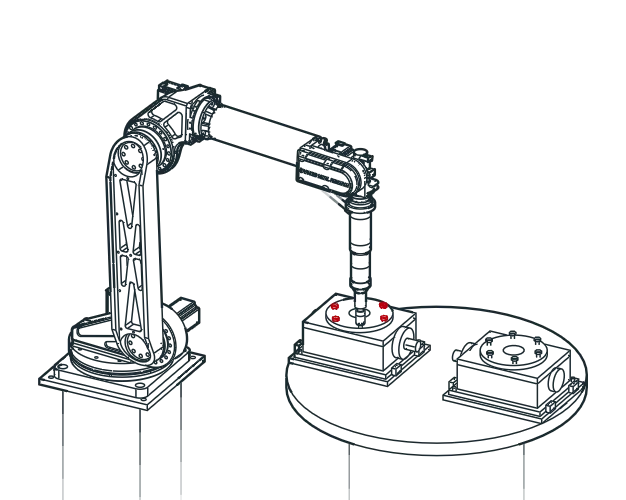 04
Assembly
A nutrunner torques a gearbox cover's six bolts in a star pattern.
-
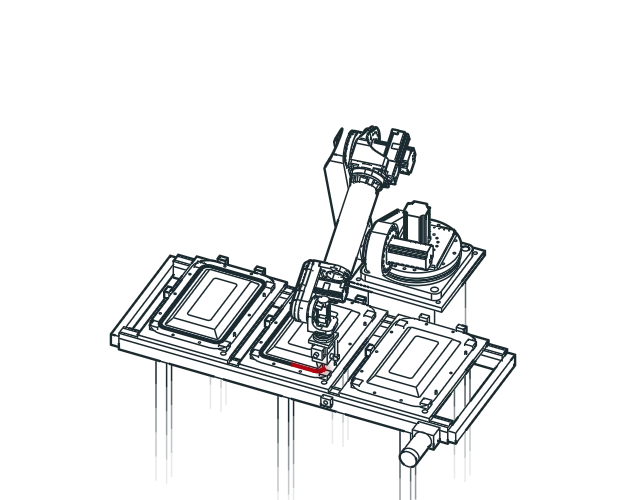 05
Dispensing
A dispensing valve lays a continuous sealant bead around a flange.
-
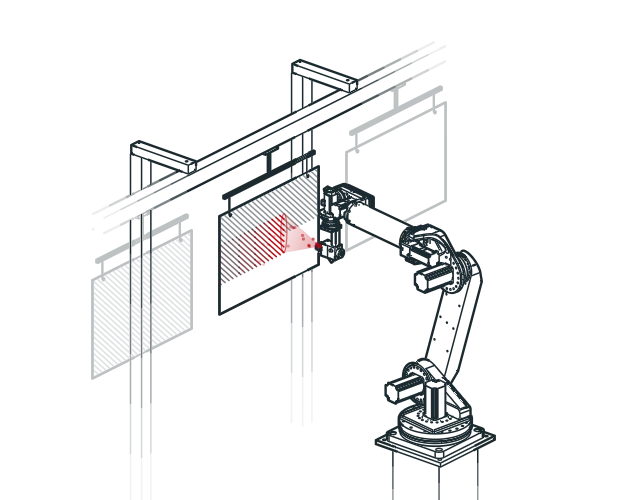 06
Coating
A spray gun covers a panel in overlapping passes at a constant standoff.
-
 07
Deburring
A compliant spindle follows the part's edges at a set tool angle.
-
 08
Plasma cutting
A plasma torch cuts a profile from plate on a slat table.
Illustrative cycles drawn from the robot's kinematic model. Process tooling is quoted per application.
04 ControlPrograms checked before load
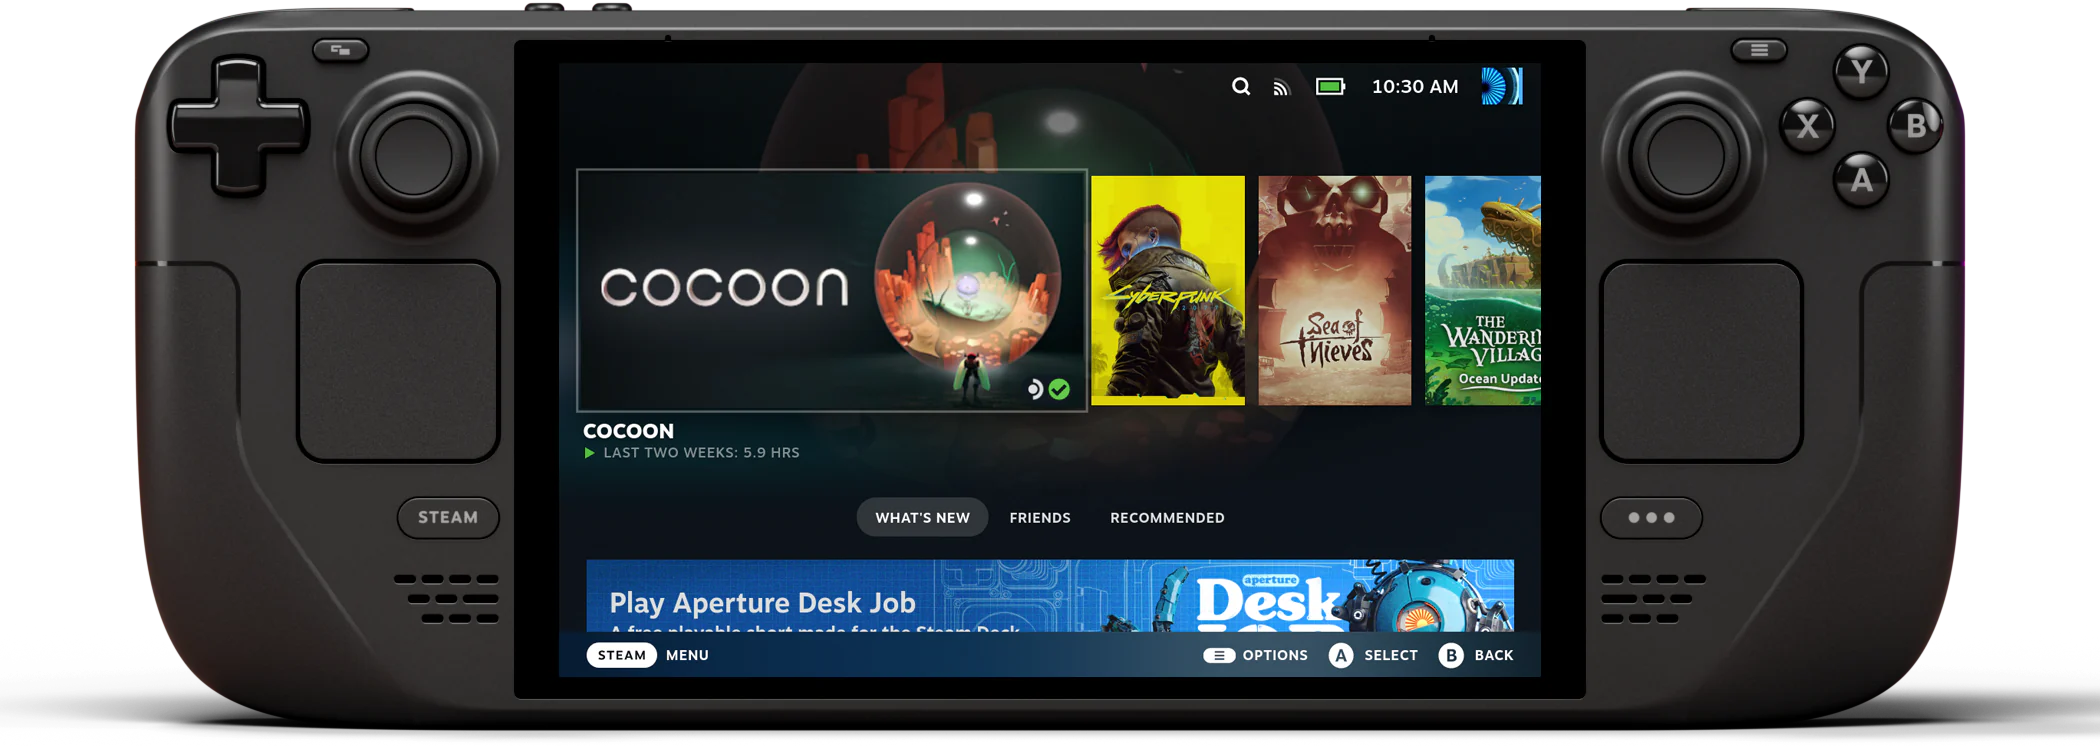
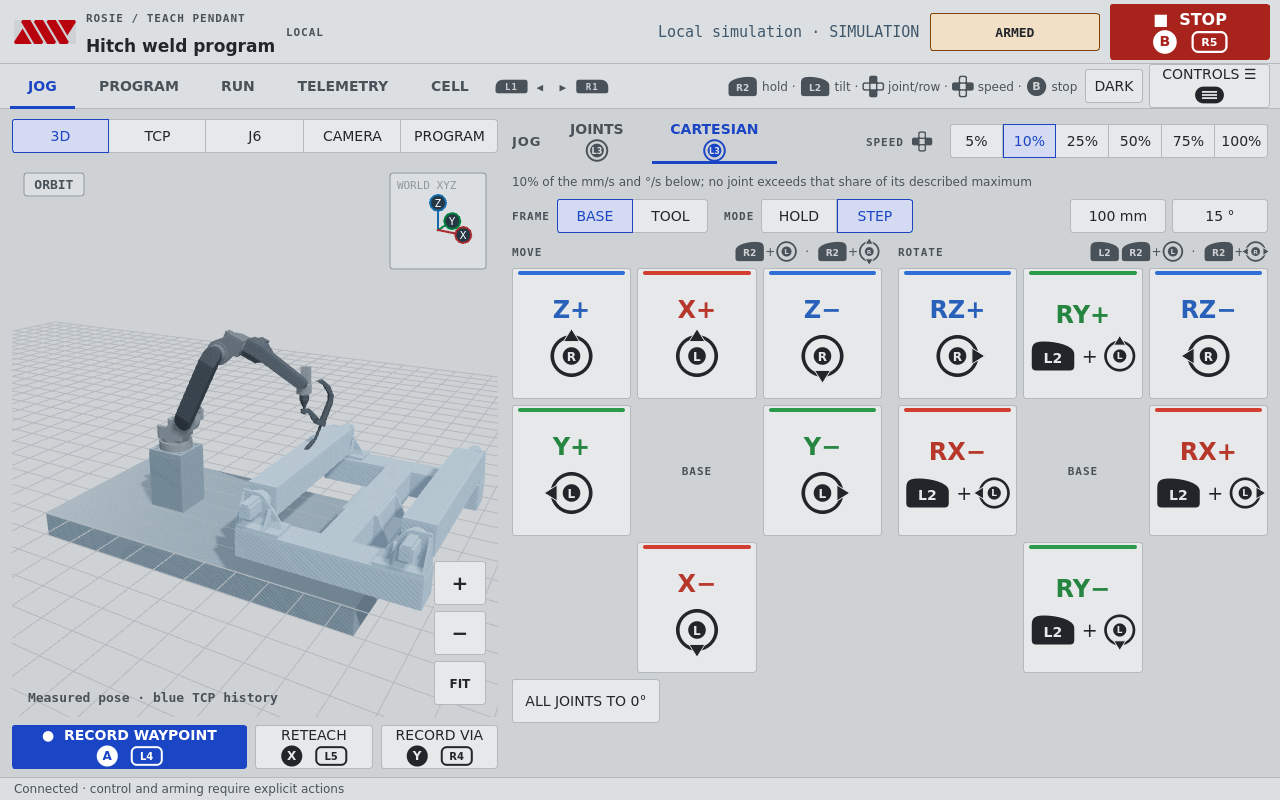
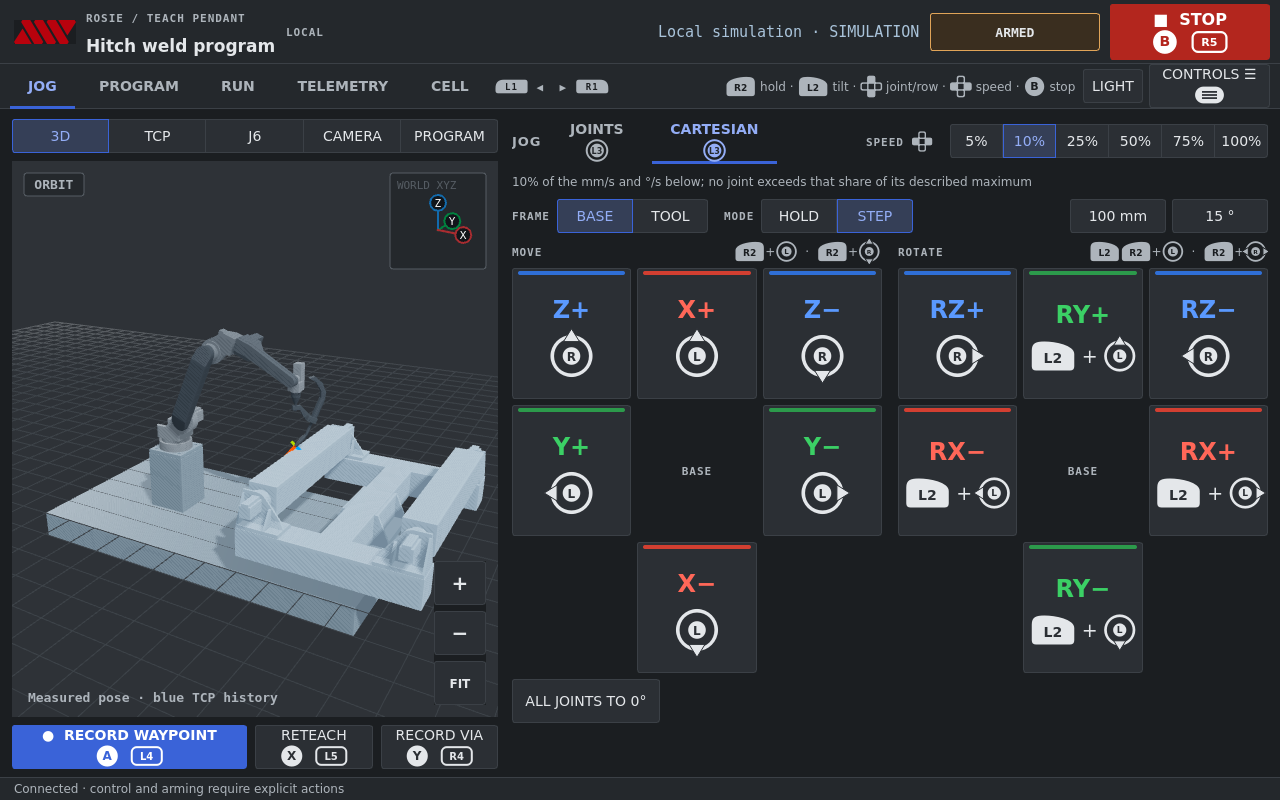
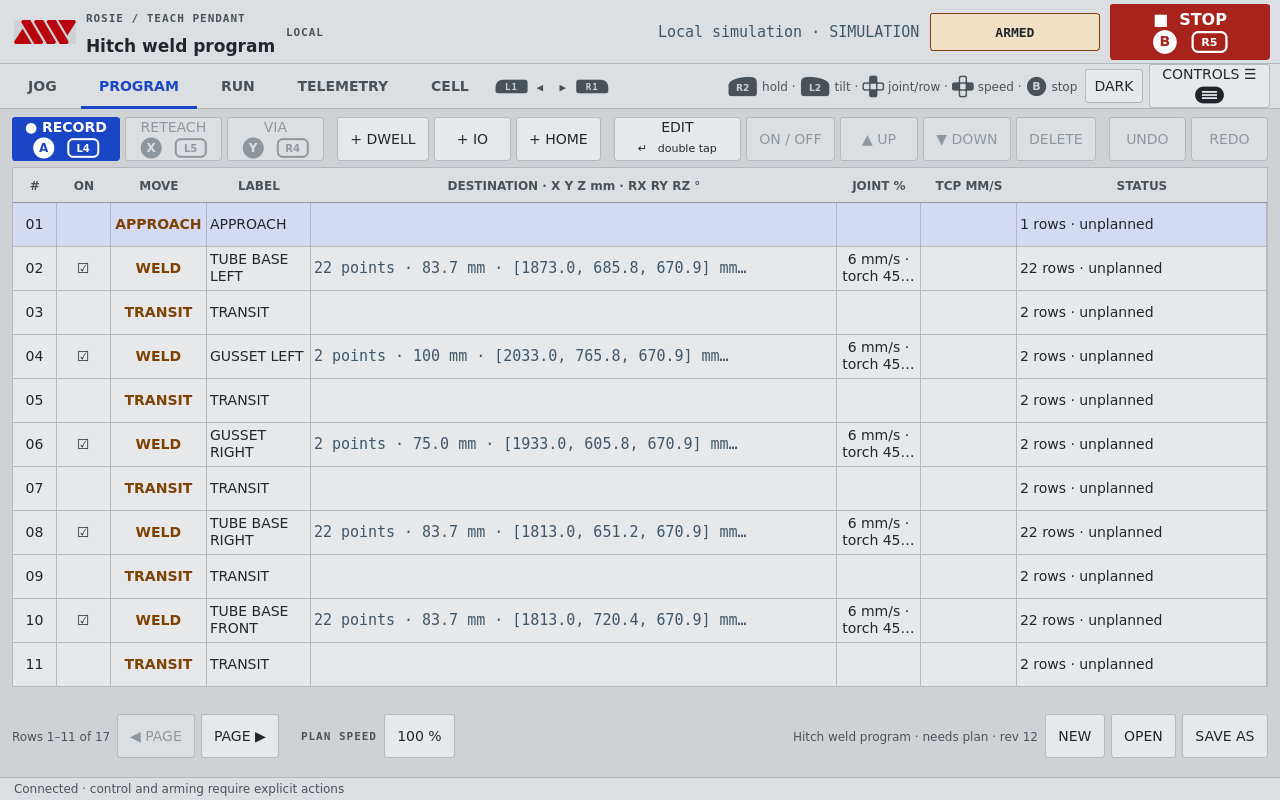
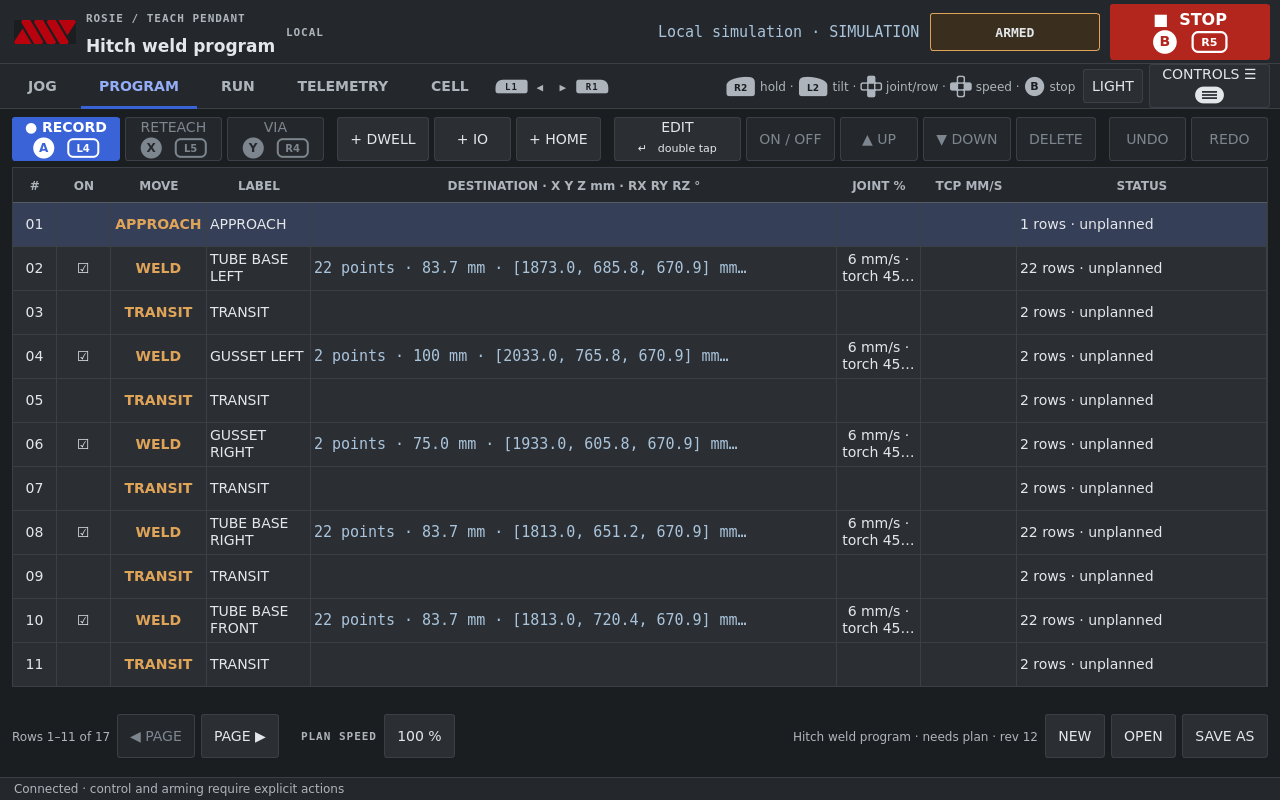
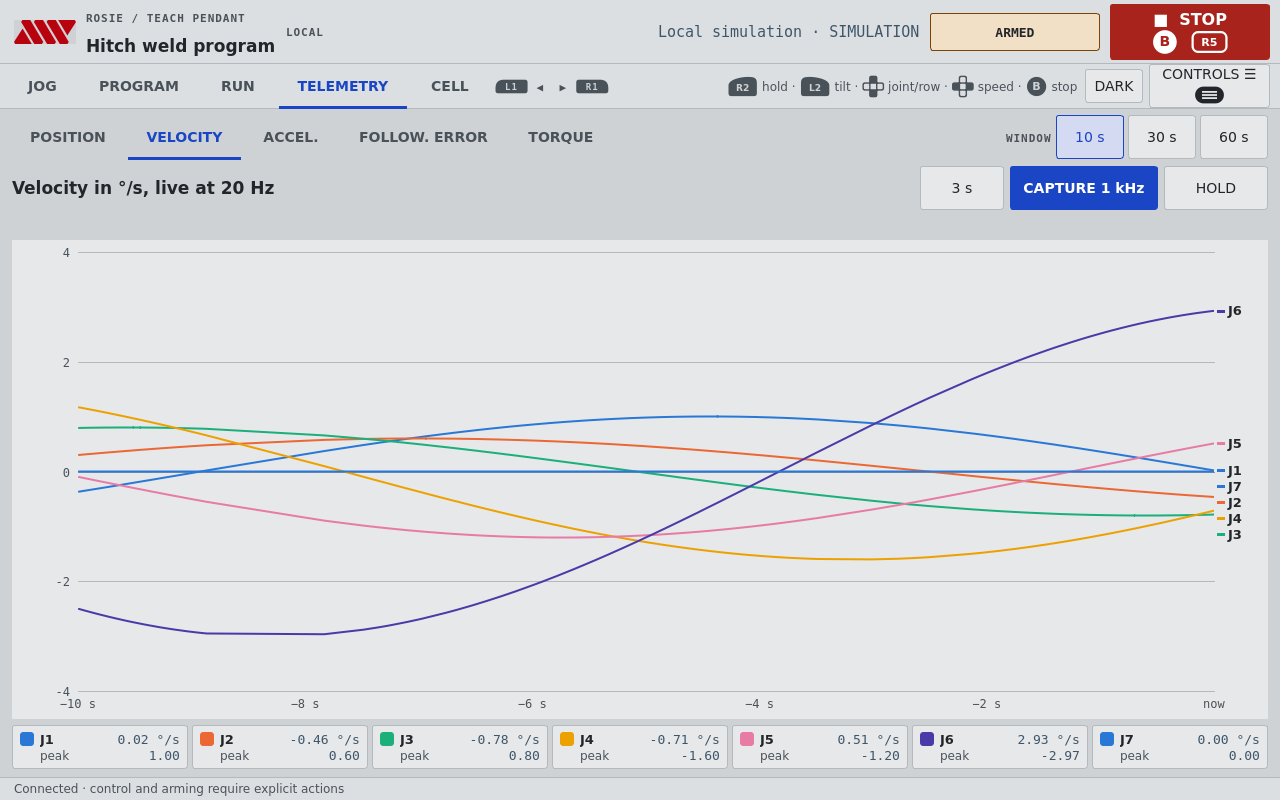
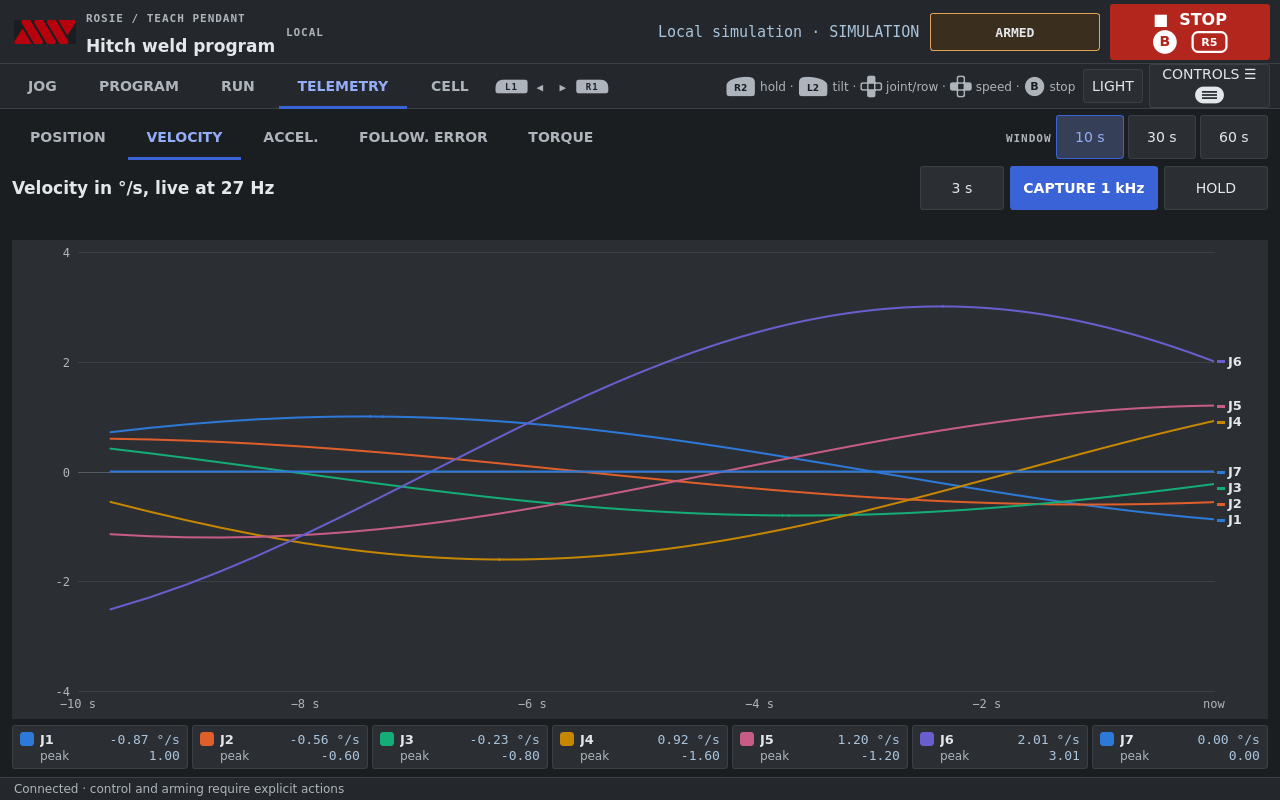
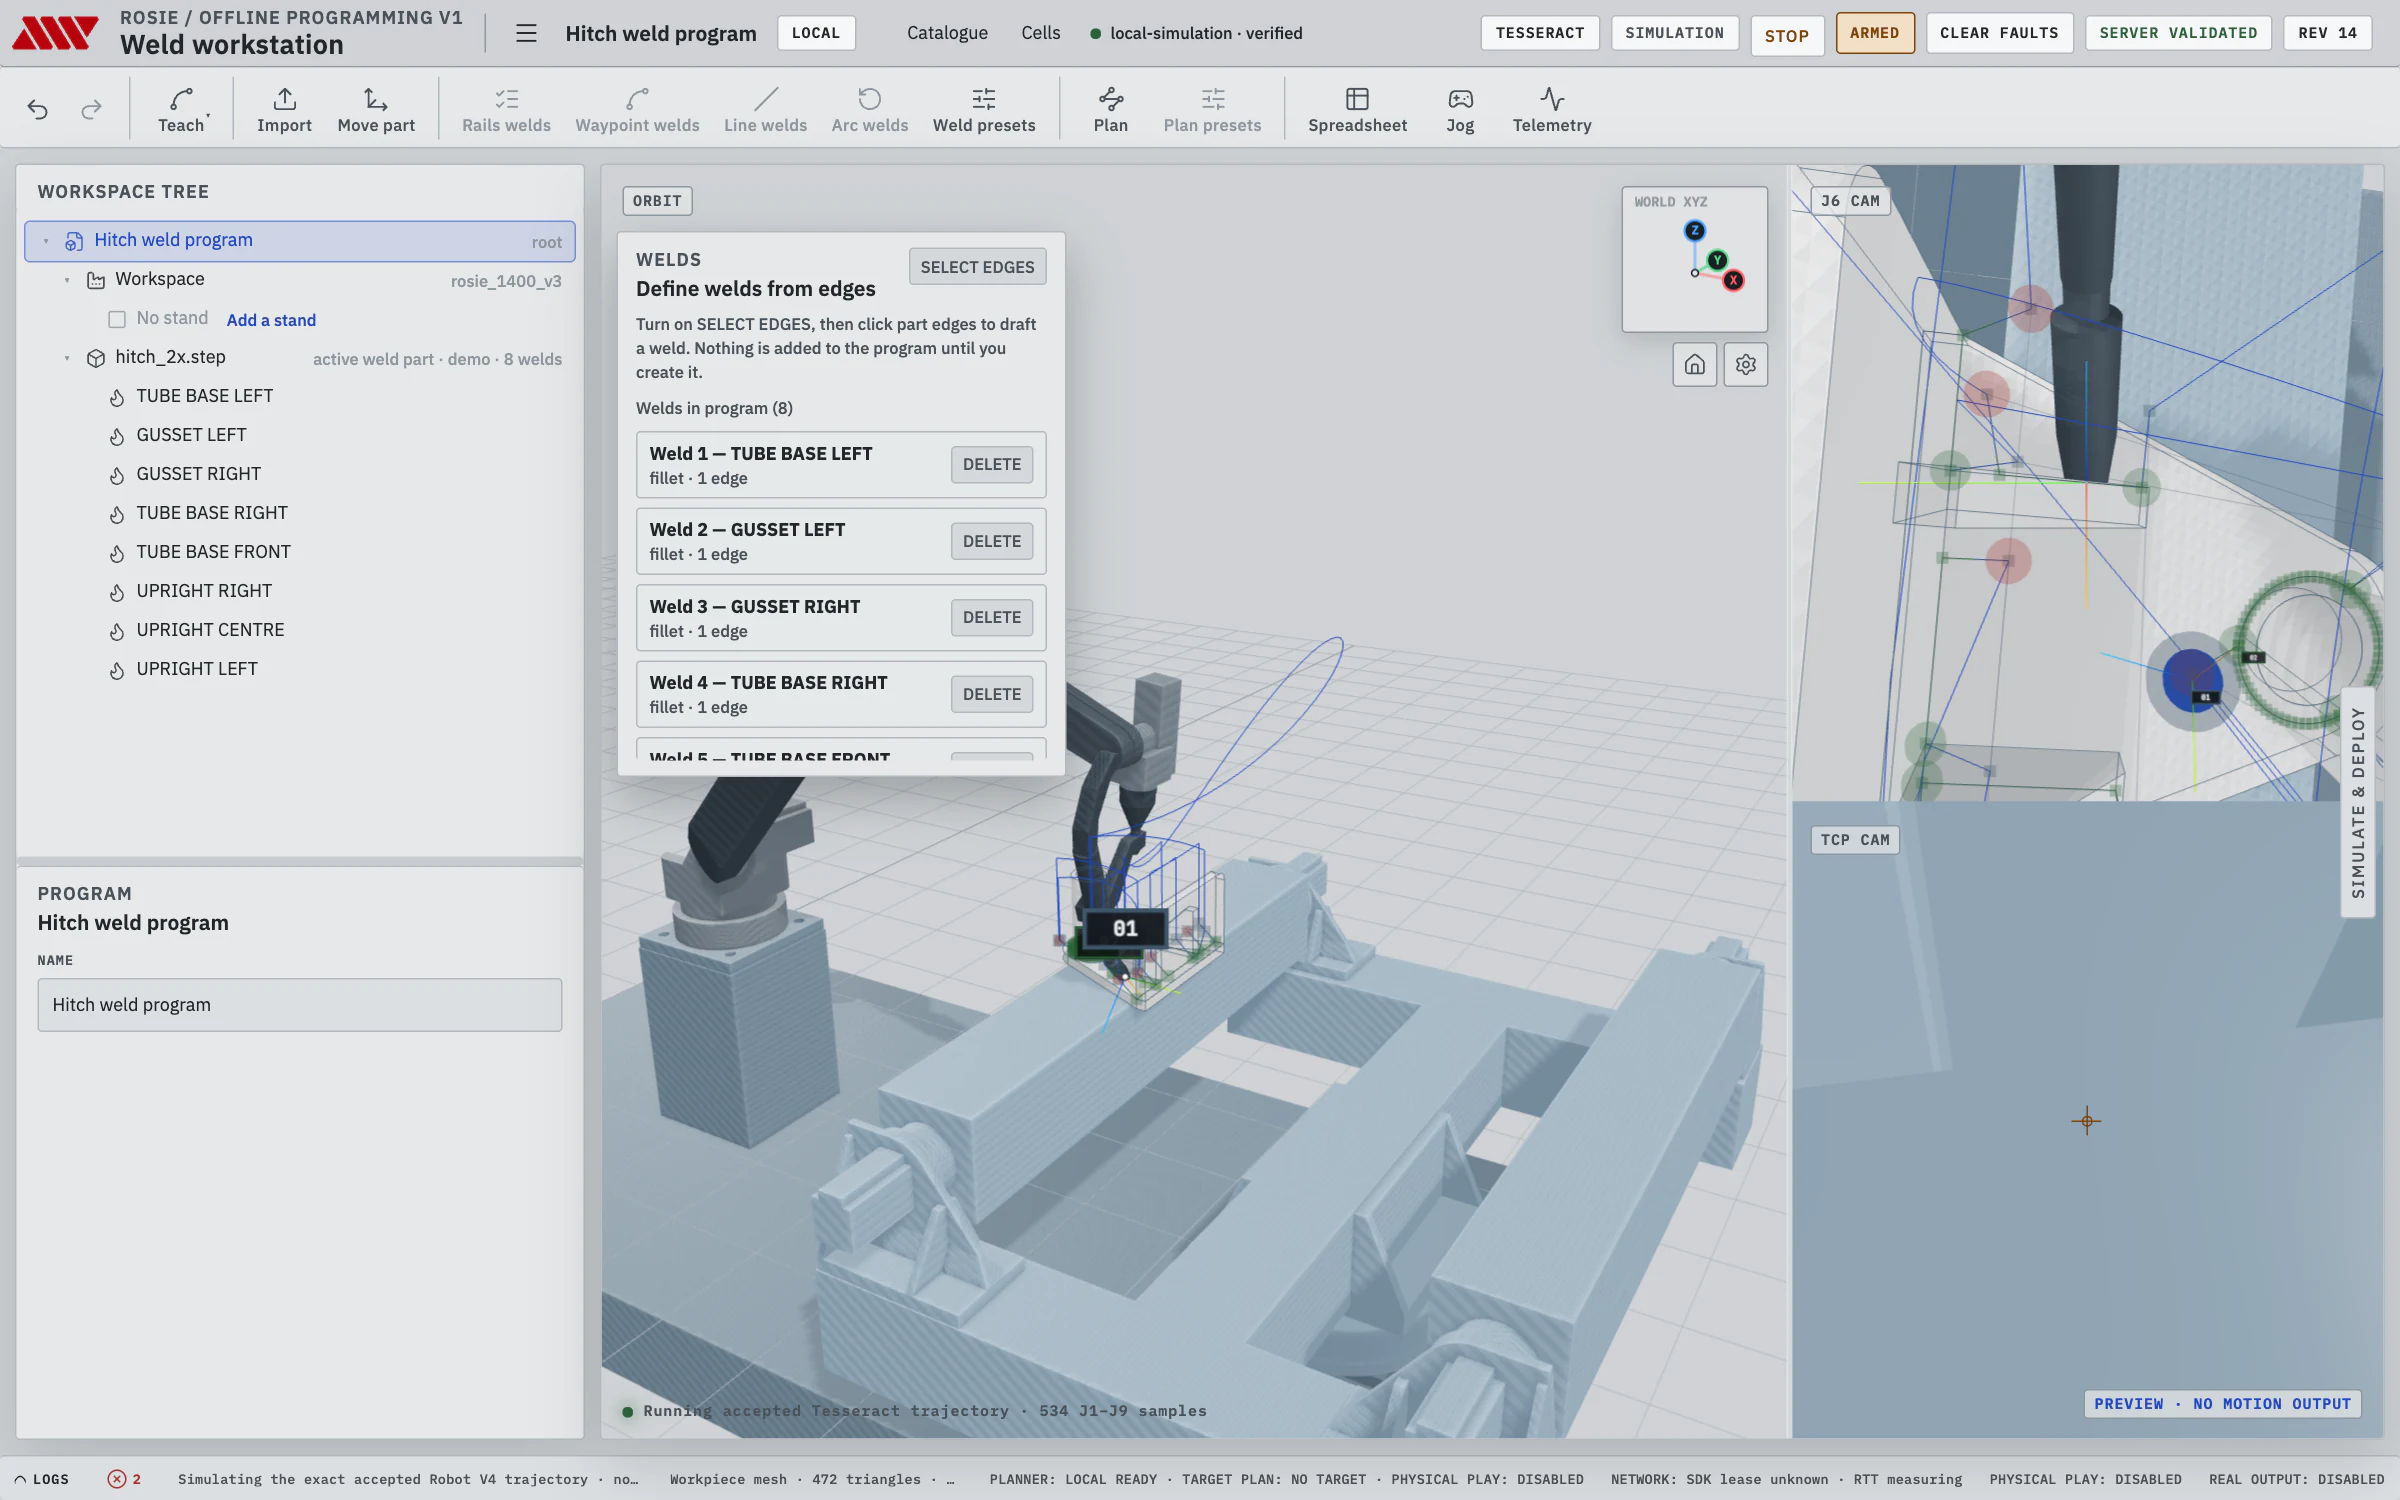
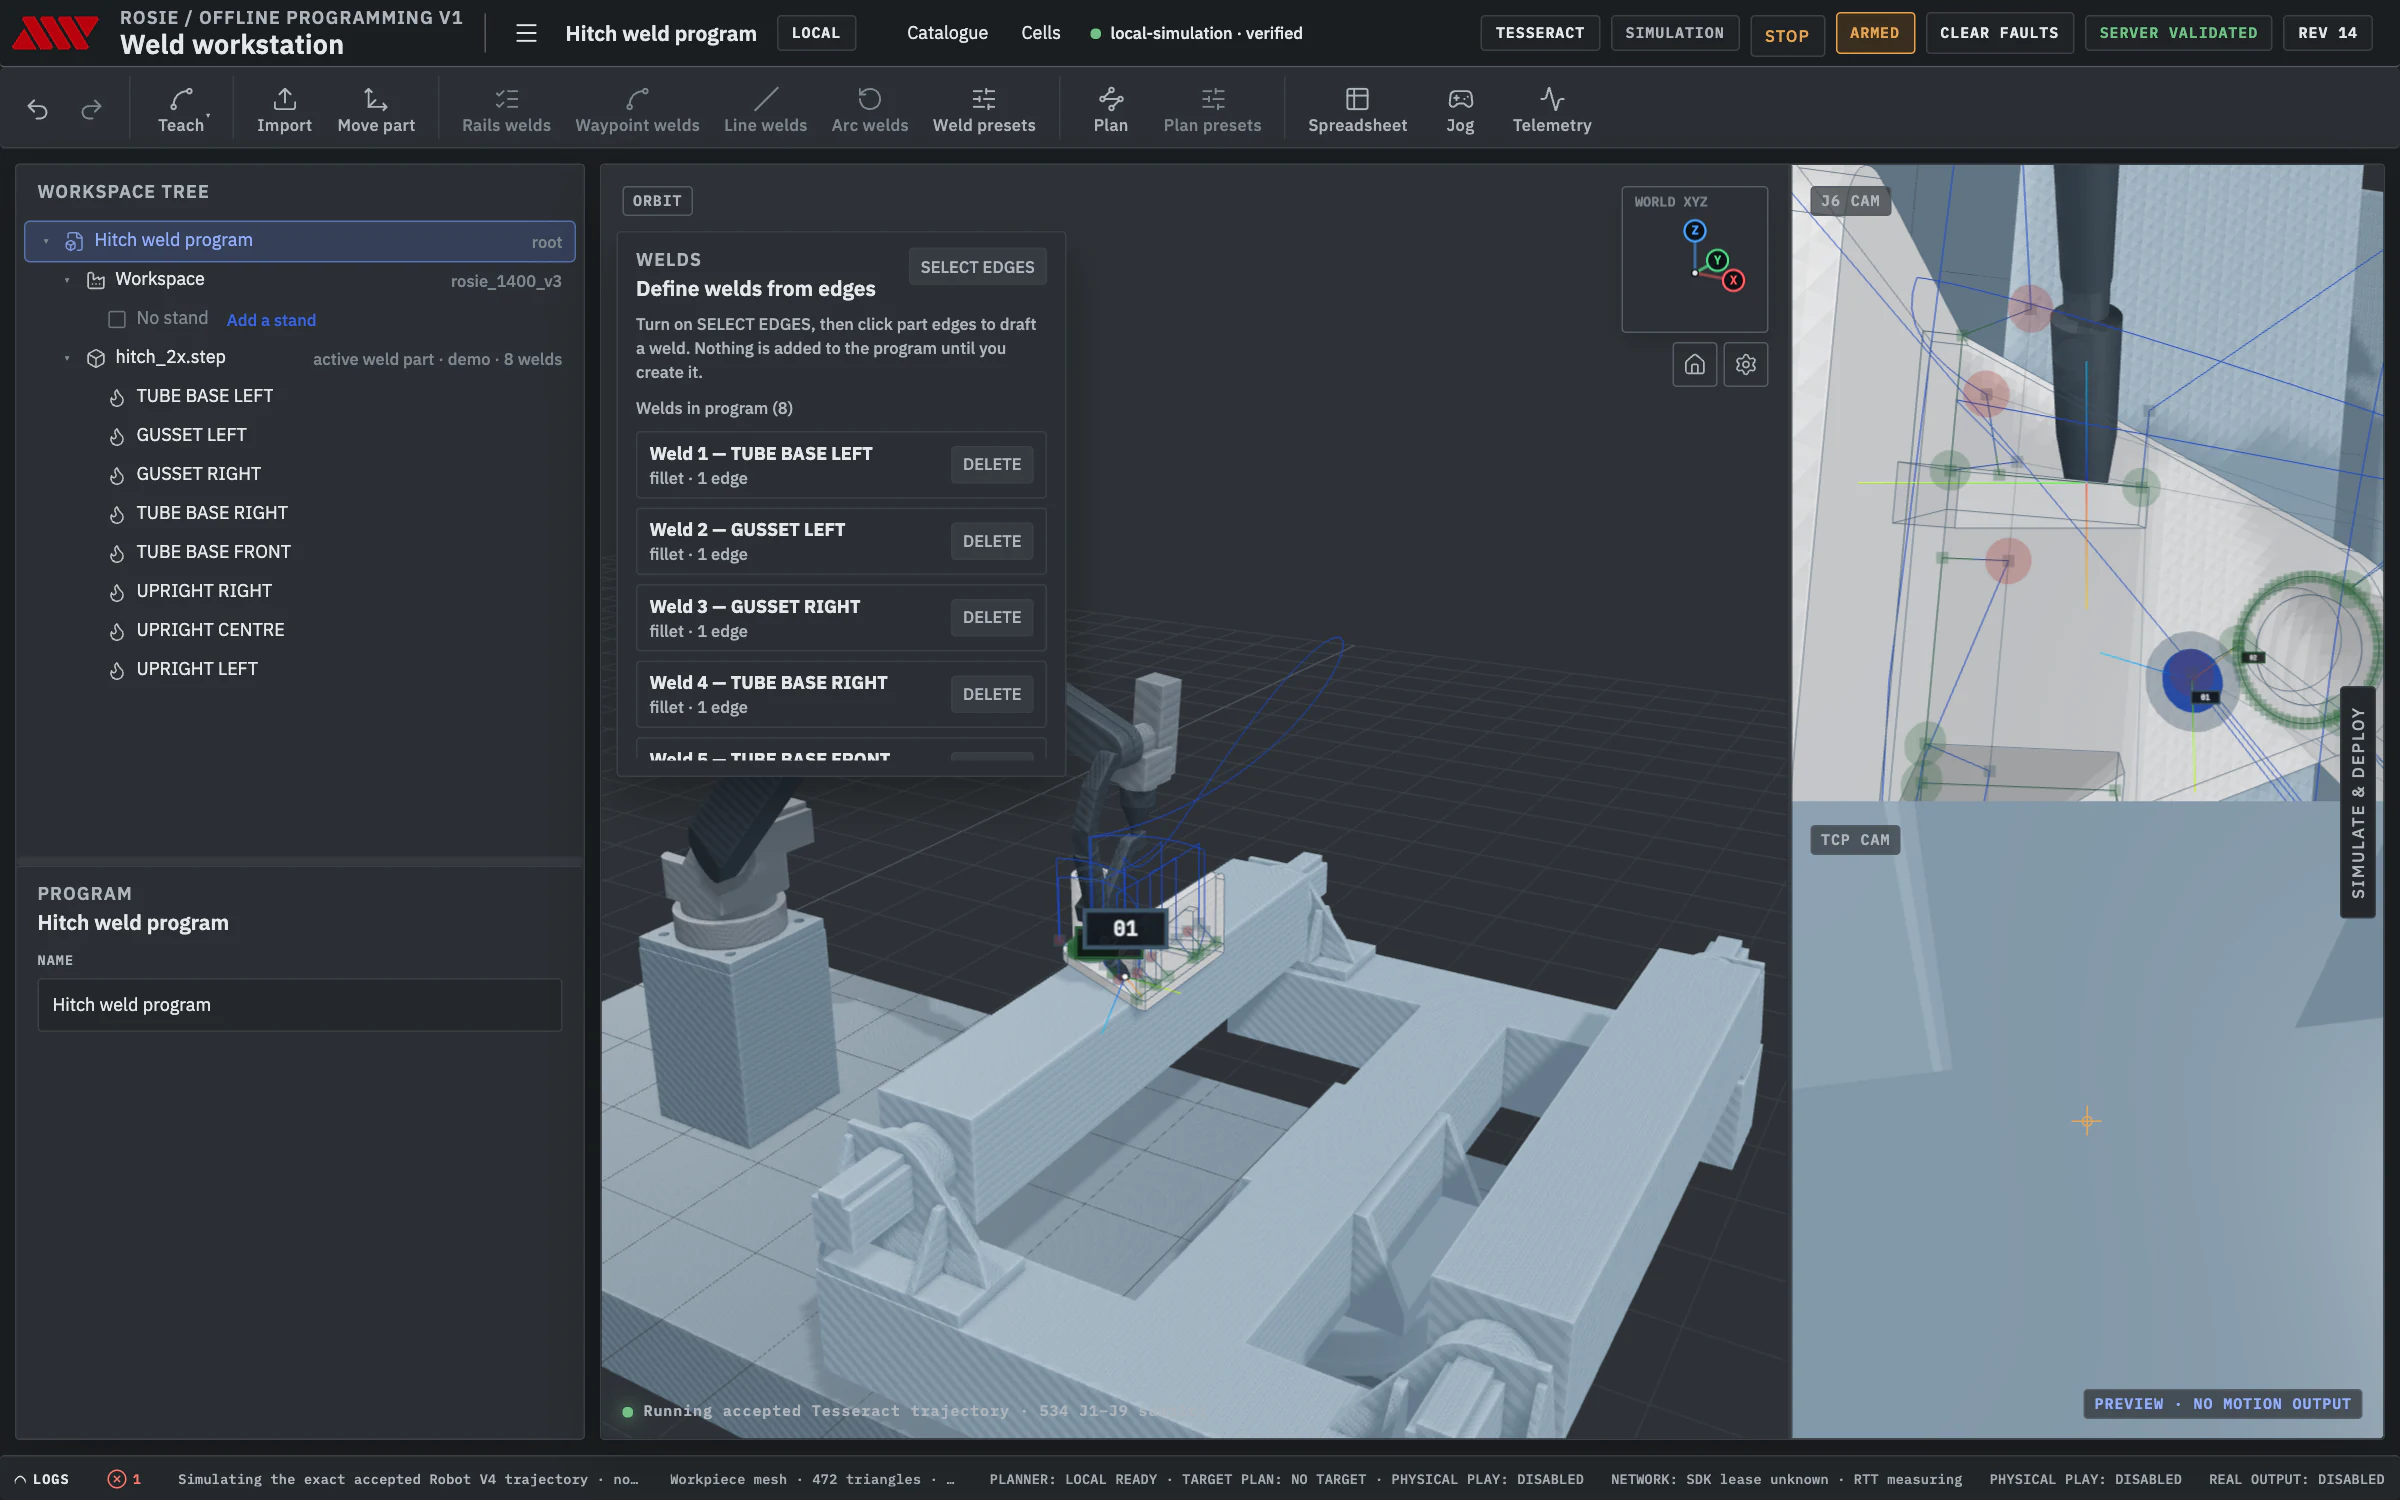
RosieOS control and a handheld pendant.
Every Rosie runs on RosieOS, AMR's real-time controller software, open source under Apache 2.0. Everything is switched on from day one: you never pay to unlock a feature the robot already has. The teach pendant is a handheld Steam Deck.
Weld programs are checked for collisions and joint limits before they can be loaded, and can be replayed in simulation before the real joints move. Operators program, jog, and run weld paths from the pendant. Programs, offsets, and procedures are stored on the controller and travel with the machine.
05 SpecificationRosie 600 Rosie 1000 Rosie 1400
Specification
The figures needed to specify, install, and integrate each Rosie.
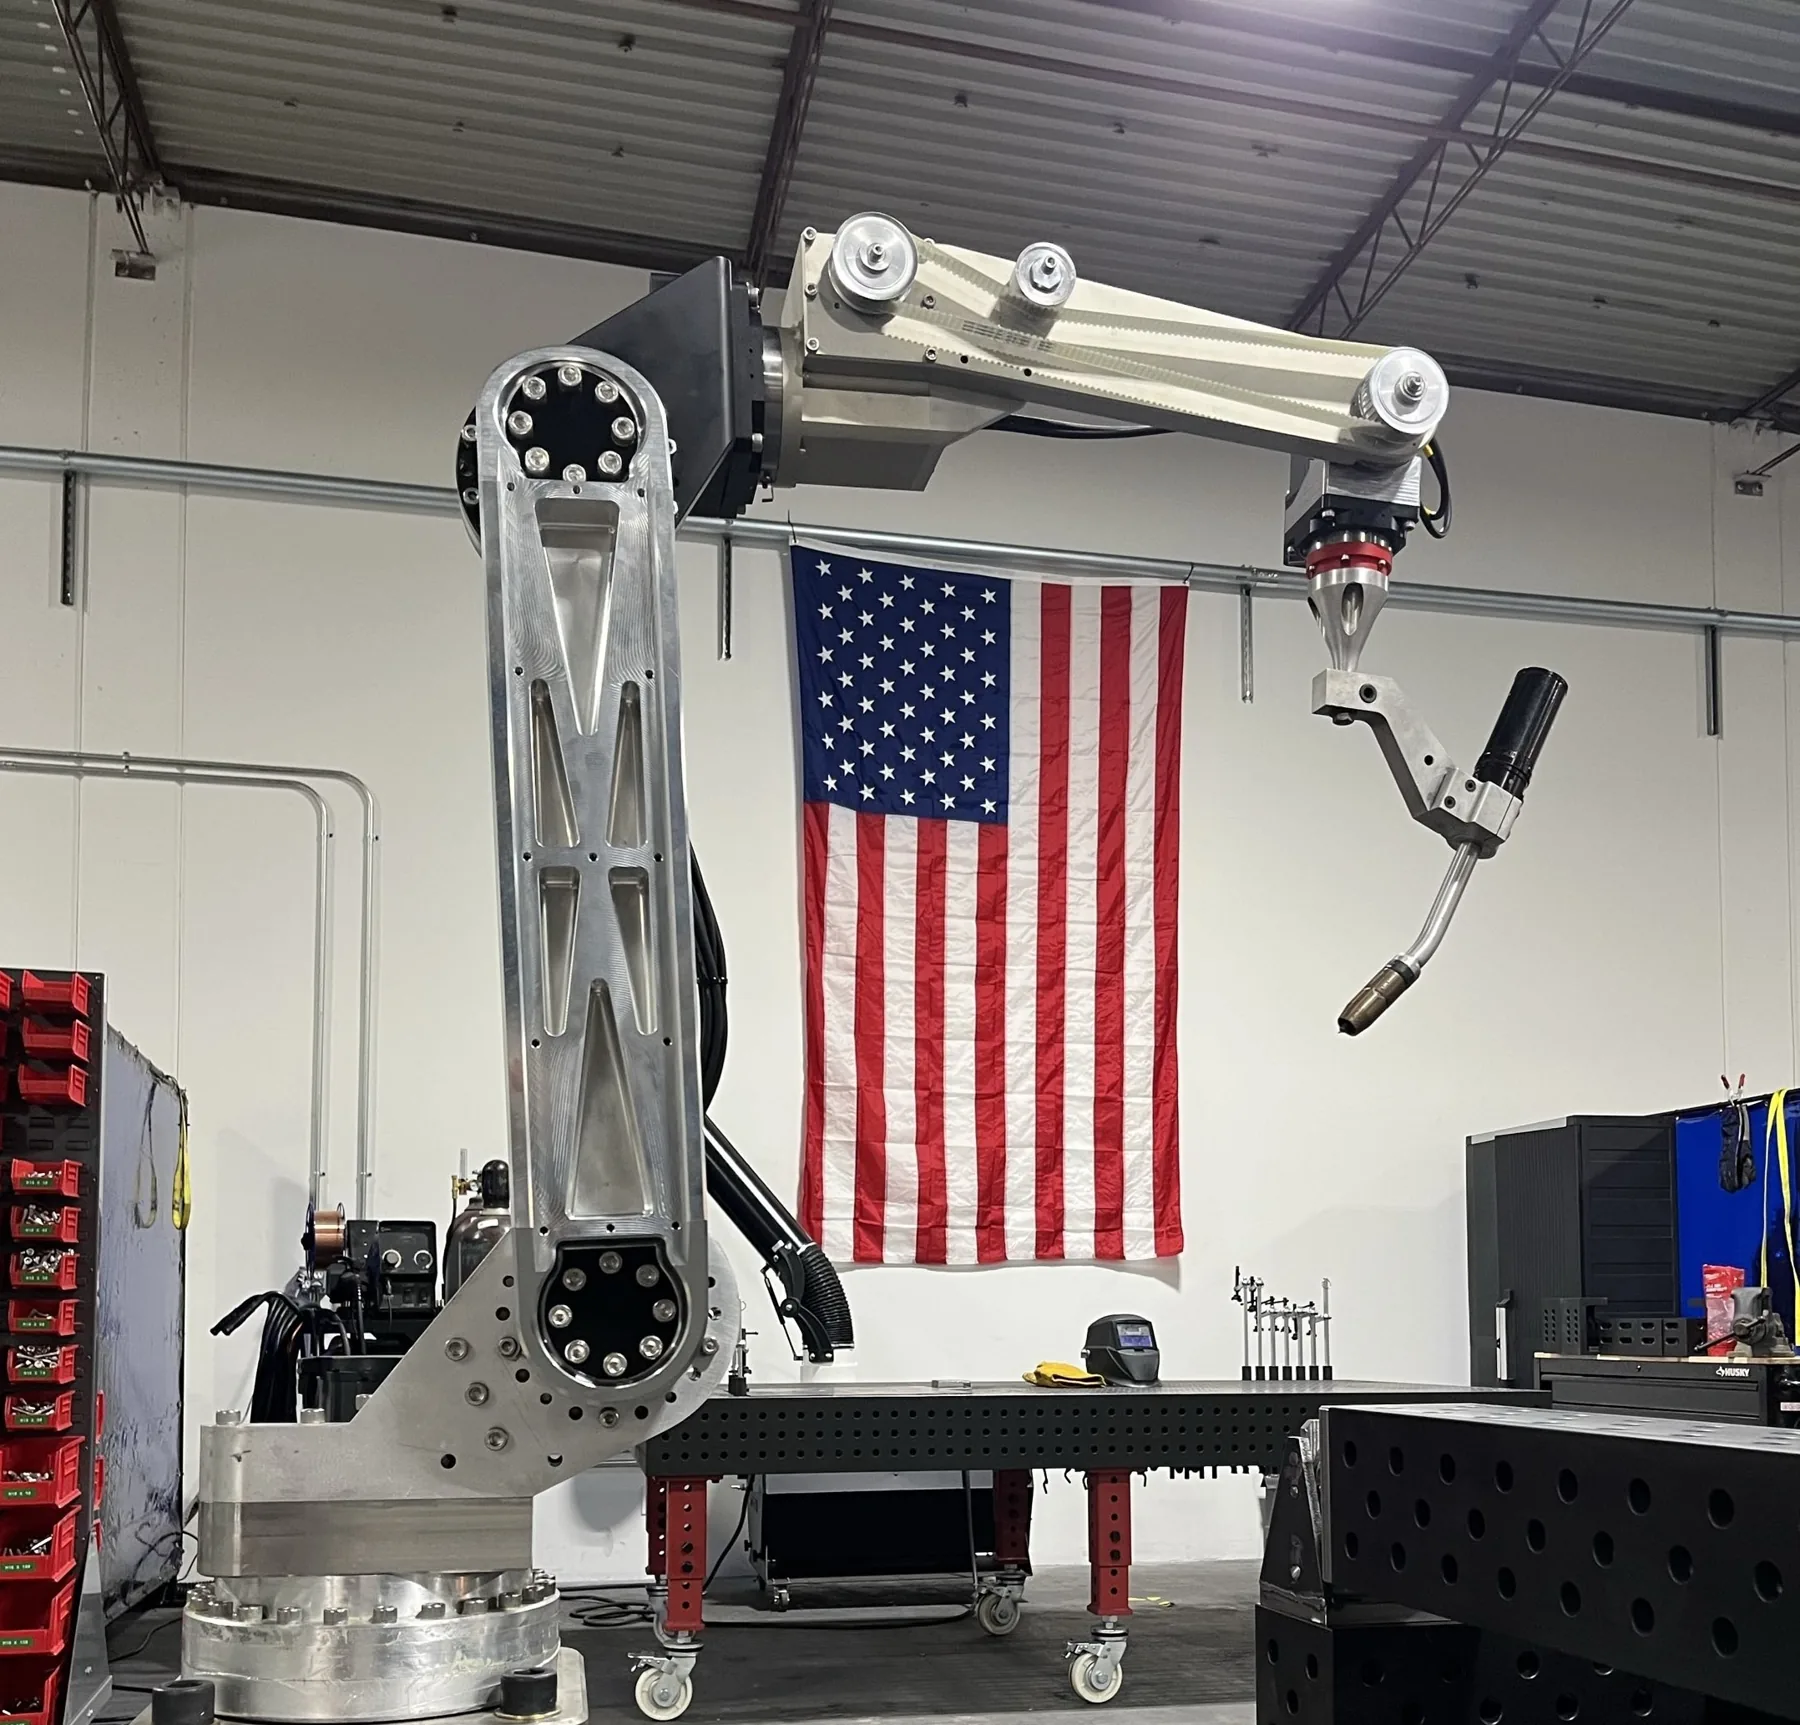
Rosie 600
- Axes
- 6
- Reach, wrist centre
- 600 mm
- Reach, tool flange
- 677 mm
- Payload, rated
- 9.0 kg
- Payload, peak torque
- 29.7 kg
- Cycle, 25 / 305 / 25 mm, 1 kg
- 0.621 s
- Cycle at rated payload
- 0.814 s
- Tool speed, peak
- 4.3 m/s
- Repeatability
- ±0.03 mm
- Mass
- 29.3 kg
- Height at home, width
- 734 mm, 213 mm
- Supply
- 220–240 VAC, single-phase, 16 A circuit
- Power, peak / average
- 1.50 kW / 358 W
- Line current, peak / average
- 10.8 A / 2.6 A
- Base
- Ø230 floor plate, 6 × M10 anchors
- Tool flange
- ISO 9409-1-50-4-M6
Pre-order Rosie 600 · $500 deposit $14,900 launch price
Rosie 1000
- Axes
- 6
- Reach, wrist centre
- 1,000 mm
- Reach, tool flange
- 1,077 mm
- Payload, rated
- 7.4 kg
- Payload, peak torque
- 29.7 kg
- Cycle, 25 / 305 / 25 mm, 1 kg
- 0.665 s
- Cycle at rated payload
- 0.801 s
- Tool speed, peak
- 6.6 m/s
- Repeatability
- ±0.04 mm
- Mass
- 38.6 kg
- Height at home, width
- 934 mm, 267 mm
- Supply
- 220–240 VAC, single-phase, 20 A circuit
- Power, peak / average
- 2.27 kW / 422 W
- Line current, peak / average
- 16.4 A / 3.1 A
- Base
- Ø230 floor plate, 6 × M10 anchors
- Tool flange
- ISO 9409-1-50-4-M6
Pre-order Rosie 1000 · $500 deposit $19,900 launch price
Rosie 1400
- Axes
- 6
- Reach, wrist centre
- 1,400 mm
- Reach, tool flange
- 1,499 mm
- Payload, rated
- 15 kg
- Payload, peak torque
- 23.4 kg
- Cycle, 25 / 305 / 25 mm, 1 kg
- 0.803 s
- Cycle at rated payload
- 0.845 s
- Tool speed, peak
- 6.6 m/s
- Repeatability
- ±0.05 mm
- Mass
- 77.0 kg
- Height at home, width
- 949 mm, 299 mm
- Supply
- 200 to 240 VAC, 3-phase, 35 A
- Power, peak / average
- 4.15 kW / 745 W
- Line current, peak / average
- 17.4 A / 3.1 A per phase
- Base
- 300 × 300 mm plate, 4 × Ø26 on 250 mm square
- Tool flange
- Ø38 face, 6 × M5 on PCD 27, ISO 50 adapter
Pre-order Rosie 1400 · $500 deposit $29,000 · deliveries begin Q1 2027
Rosie 1400 is made in the USA, from US and imported parts.
Every Rosie
- Controller
- RosieOS, built by AMR, open source under Apache 2.0
- Motion control
- Real-time, all six axes
- Teach pendant
- Handheld
- Program check
- Collision and limits before load
Drives
- Motors
- EtherCAT servos, IP67, 24 VDC holding brakes
- Encoders
- 17-bit absolute
- Installed motor power
- 1,850 W (600), 2,450 W (1000), 3,900 W (1400)
- Gearboxes
- Harmonic, all six joints, IP65 (600, 1000)
- Structure
- Machined 6061-T6 aluminum (600, 1000)
| Joint | Range, Rosie 600 and 1000 | Range, Rosie 1400 | Speed, Rosie 600 | Speed, Rosie 1000 | Speed, Rosie 1400 |
|---|---|---|---|---|---|
| J1 base | ±170° | ±177.6° | 336 °/s | 336 °/s | 240 °/s |
| J2 shoulder | ±110° | ±108.9° | 288 °/s | 240 °/s | 240 °/s |
| J3 elbow | ±150° | ±149.0° | 336 °/s | 288 °/s | 240 °/s |
| J4 forearm roll | ±180° | ±177.6° | 360 °/s | 360 °/s | 336 °/s |
| J5 wrist bend | ±125° | ±126.1° | 360 °/s | 360 °/s | 360 °/s |
| J6 flange roll | ±180° | ±177.6° | 360 °/s | 360 °/s | 360 °/s |
06 CAD and simulationSTEP URDF MuJoCo Free download
CAD and simulation
STEP, URDF and MuJoCo models of all three Rosie robots, with full kinematics, joint limits, speeds, torques and mass properties.
The models carry the robot's real outside surfaces: each link is one solid, filled inside, with the structural parts' own CAD faces and the motors and gearboxes as plain envelopes of the same size, so you can dimension from them and design a pedestal or tool against them. Every number is also in robot.json, including joint accelerations and the exact conditions of the published cycle times, and each kit has tested quickstart code for PyBullet, MuJoCo and ROS 2. Each kit also carries the benchmark cycle as a timestamped joint trajectory, IK reference cases solved by RosieOS's own solver, and a GLB that loads straight into a browser. Joint names and the home pose match RosieOS. Drawings and STEP files of the Rosie 1400 base and tool flange are in the docs under Mechanical interfaces.
Download the kit · ZIP, 700 KB
Rosie 1000
1,000 mm reach 38.6 kgRosie 1400
1,400 mm reach 77.0 kgRun it in simulation
Shown for the Rosie 1000. For the other robots, change 1000 to 600 or 1400.
TerminalBash
curl -LO https://advancedmetalresearch.com/assets/sim/rosie-1000-sim-kit.zip
unzip -q rosie-1000-sim-kit.zip && cd rosie_1000_description
pip install mujoco pybullet numpy
python examples/mujoco_demo.py      # also: pybullet_demo.py, fk_ik.py
mujoco_hold.py, in rosie_1000_descriptionPython
import mujoco
import numpy as np

model = mujoco.MjModel.from_xml_path("mjcf/rosie_1000.xml")
data = mujoco.MjData(model)
data.ctrl[:] = np.radians([30, 45, -10, 0, -35, 0])   # position servos on J1..J6
for _ in range(1500):                                  # 3 s at 2 ms steps
    mujoco.mj_step(model, data)
print(np.degrees(data.qpos).round(2))                  # joint angles (deg)
print(data.actuator_force.round(1))                    # joint torques (N m)
print(data.site("tool0").xpos.round(4))                # flange face (m)
pybullet_move.py, in rosie_1000_descriptionPython
import math
import pybullet as p

p.connect(p.DIRECT)                                    # p.GUI for a window
p.setGravity(0, 0, -9.81)
robot = p.loadURDF("urdf/rosie_1000.urdf", useFixedBase=True,
                   flags=p.URDF_USE_INERTIA_FROM_FILE)
joints = [p.getJointInfo(robot, i) for i in range(p.getNumJoints(robot))]
arm = [j for j in joints if j[2] == p.JOINT_REVOLUTE]  # J1..J6
tool0 = next(j[0] for j in joints if j[12] == b"tool0")

target = [math.radians(a) for a in (30, 45, -10, 0, -35, 0)]
for j, q in zip(arm, target):                          # j[10] peak torque, j[11] max speed
    p.setJointMotorControl2(robot, j[0], p.POSITION_CONTROL, targetPosition=q,
                            force=j[10], maxVelocity=j[11])
for _ in range(3 * 240):
    p.stepSimulation()
print(p.getLinkState(robot, tool0, computeForwardKinematics=True)[4])
Terminal, in a ROS 2 workspaceBash
cp -r rosie_1000_description ~/ros2_ws/src/
cd ~/ros2_ws && colcon build --packages-select rosie_1000_description
source install/setup.bash
ros2 launch rosie_1000_description display.launch.py   # RViz with joint sliders
fk.py, numpy onlyPython
import json
import urllib.request

import numpy as np

URL = "https://advancedmetalresearch.com/assets/sim/1000/robot.json"
req = urllib.request.Request(URL, headers={"User-Agent": "rosie-sim-kit/1.0"})
robot = json.load(urllib.request.urlopen(req))


def rot(axis, q):
    x, y, z = axis
    c, s, t = np.cos(q), np.sin(q), 1 - np.cos(q)
    return np.array([[t * x * x + c, t * x * y - s * z, t * x * z + s * y],
                     [t * x * y + s * z, t * y * y + c, t * y * z - s * x],
                     [t * x * z - s * y, t * y * z + s * x, t * z * z + c]])


def fk(q):
    """Pose of tool0 (4x4) in base_link for joint angles q (rad)."""
    T = np.eye(4)
    for j, qi in zip(robot["joints"], q):
        A = np.eye(4)
        A[:3, 3], A[:3, :3] = j["origin_xyz"], rot(j["axis"], qi)
        T = T @ A
    return T @ np.diag([1, -1, -1, 1])                 # tool0: z out of the flange


print(fk(robot["poses"]["stretched"])[:3, 3])          # (m)
Units are metres, kilograms and radians; the STEP is in millimetres. At home every joint is zero, the forearm points along +x and the tool flange faces down. tool0 is the flange face, z out of the flange. Every file has a stable URL under /assets/sim/, and the guide Simulate a Rosie robot covers frames, ratings and the RosieOS simulator.
07 Options
Configured to order.
Tell us what Rosie needs to move, carry, or position, and we will recommend the reach and prepare a proposal. Every robot ships with the arm, controller, drives, cabling, pendant, and commissioning at your site.
- Arm and controller
- Rosie 600, Rosie 1000 or Rosie 1400, RosieOS controller, drives, handheld pendant, base hardware. Included with every order.
- Welding package
- MIG, TIG, or fiber laser torch with wire feed, gas, and torch-mount tooling on the ISO 50 flange. Laser packages include a 2–10 kW fiber laser source and interlocks.
- War Machine
- Rosie 1400 is also available as the robot inside War Machine, our production welding cell. See War Machine.
08 Order
Order Rosie.
Rosie 600 is $14,900 and Rosie 1000 is $19,900, launch prices for pre-orders placed before 31 December 2026.
Pre-order Rosie 600 or Rosie 1000 with a fully refundable $500 deposit per robot. We confirm your production slot by email within one business day and send your ship date as production is scheduled. The balance, $14,400 for Rosie 600 and $19,400 for Rosie 1000, is invoiced before shipment.
Pre-order Rosie 600 with a $500 deposit
Pre-order Rosie 1000 with a $500 deposit
Rosie 1400 is $29,000. The arm, RosieOS controller, drive cabinet, cabling, pendant, and commissioning at your site are included. Welding packages are quoted per application.
Pre-order Rosie 1400 with a fully refundable $500 deposit per robot. Deliveries begin Q1 2027. We confirm your production slot by email within one business day and send your ship date as production is scheduled. The $28,500 balance is invoiced before shipment.
Pre-order Rosie 1400 with a $500 deposit
Prefer a written proposal first? Complete the fields that apply. We reply with a proposal, lead time, and a date to see Rosie run in Hawthorne. Not sure which reach? Pick "Help me choose" and describe the part. Sending opens a pre-filled email in your own mail client. This site stores nothing.
Or write directly to generalcontact@advancedmetalresearch.com